Innovation
Autonomous laparoscopic surgical robot
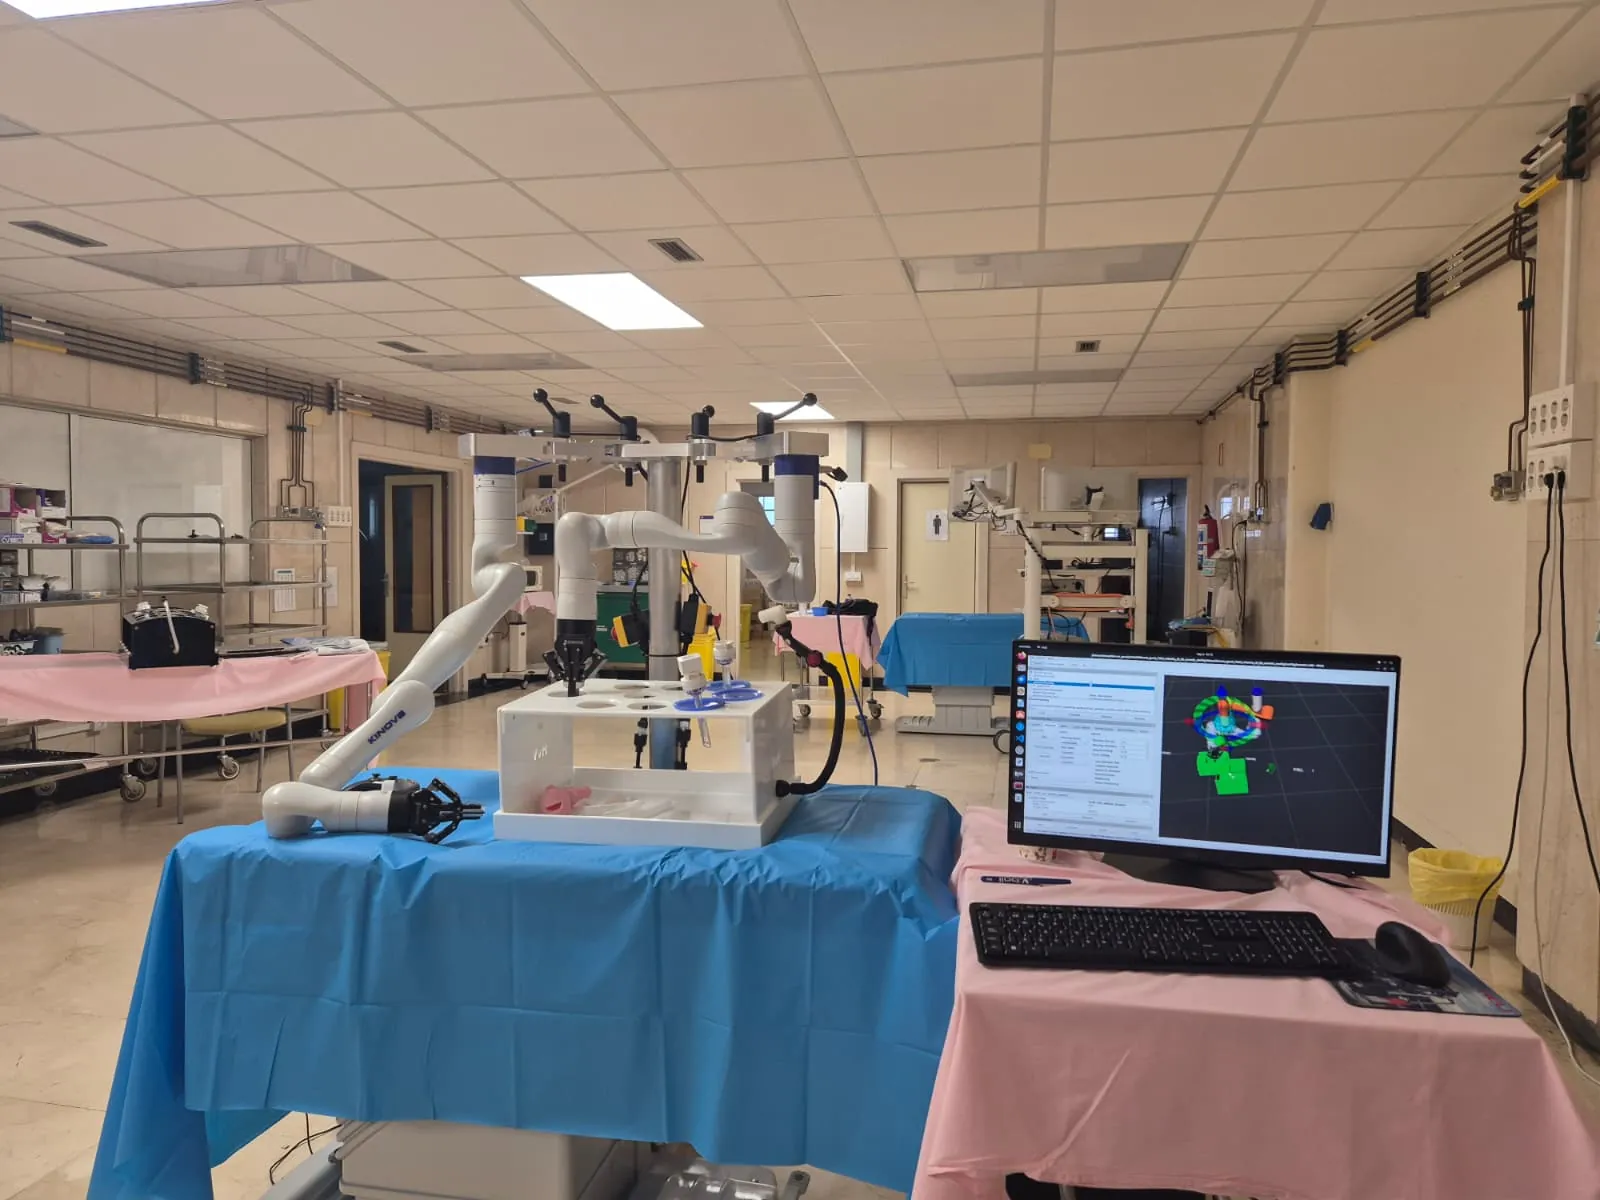
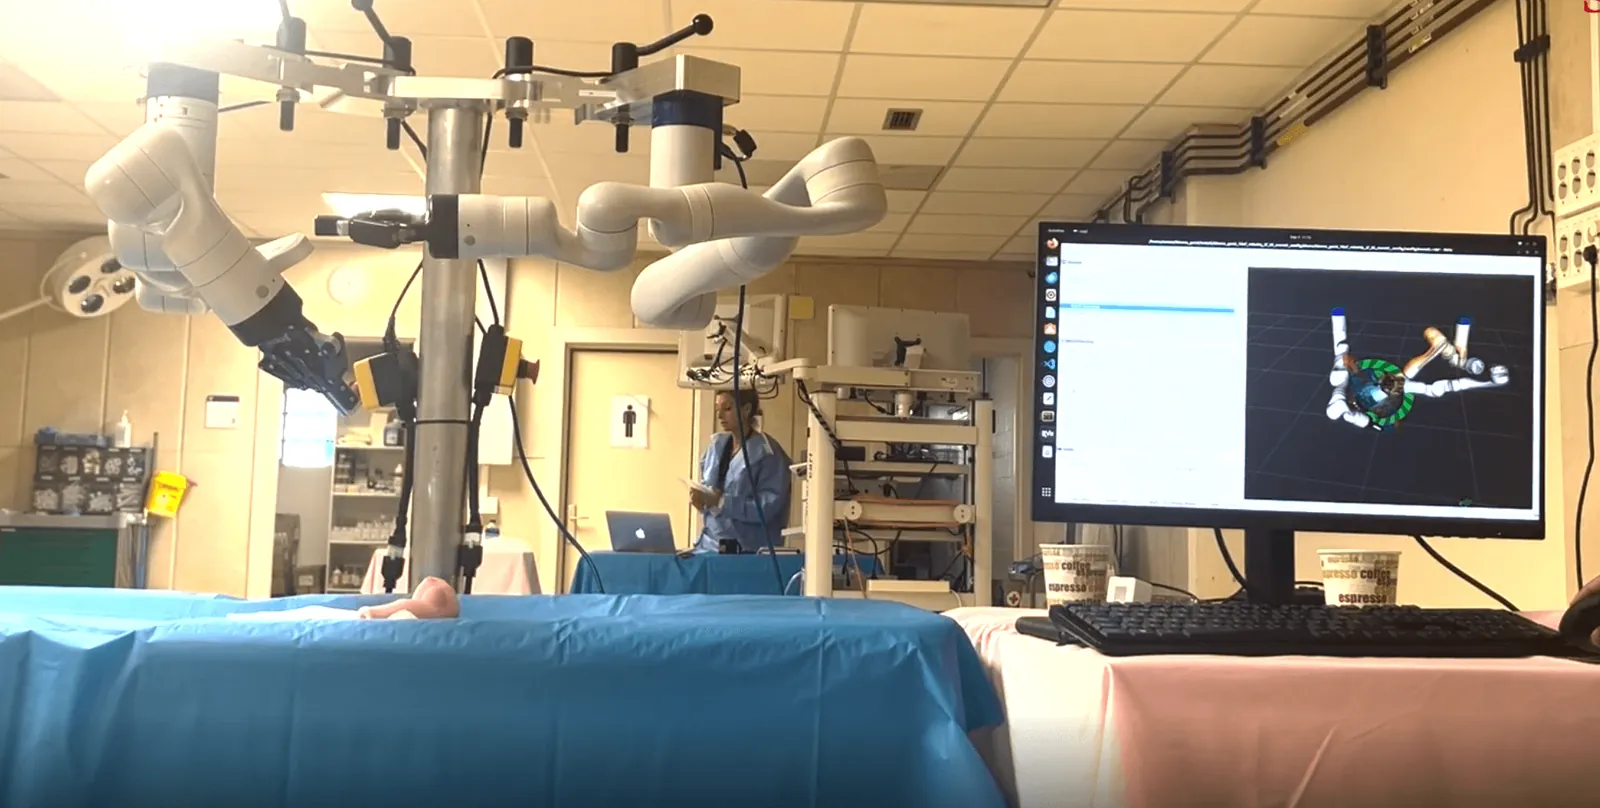
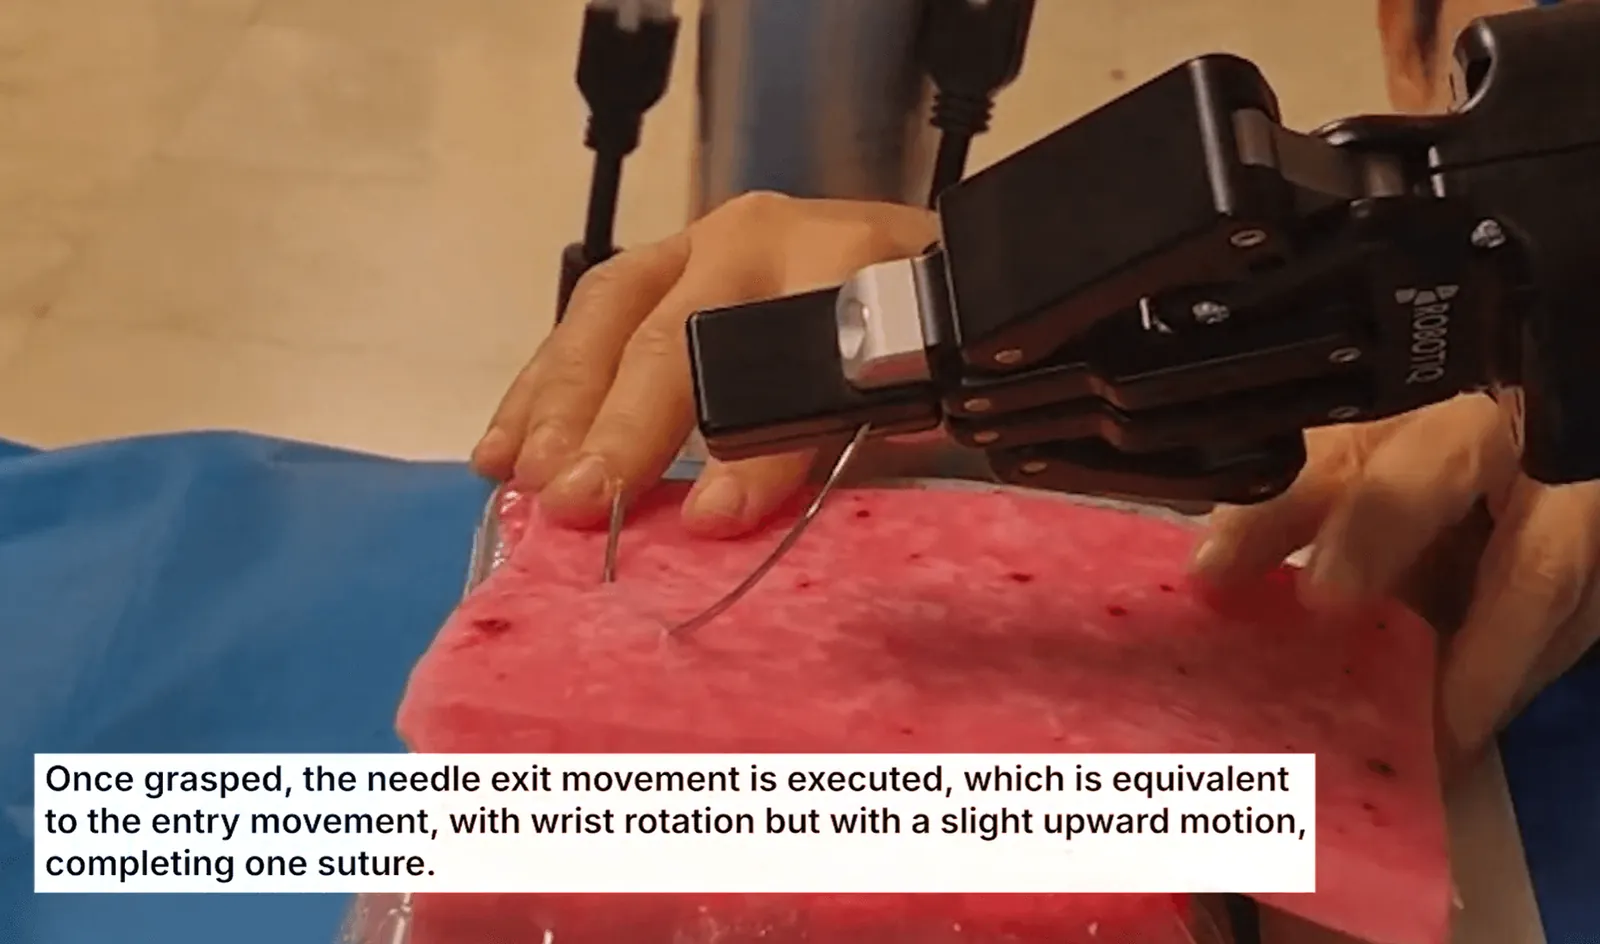
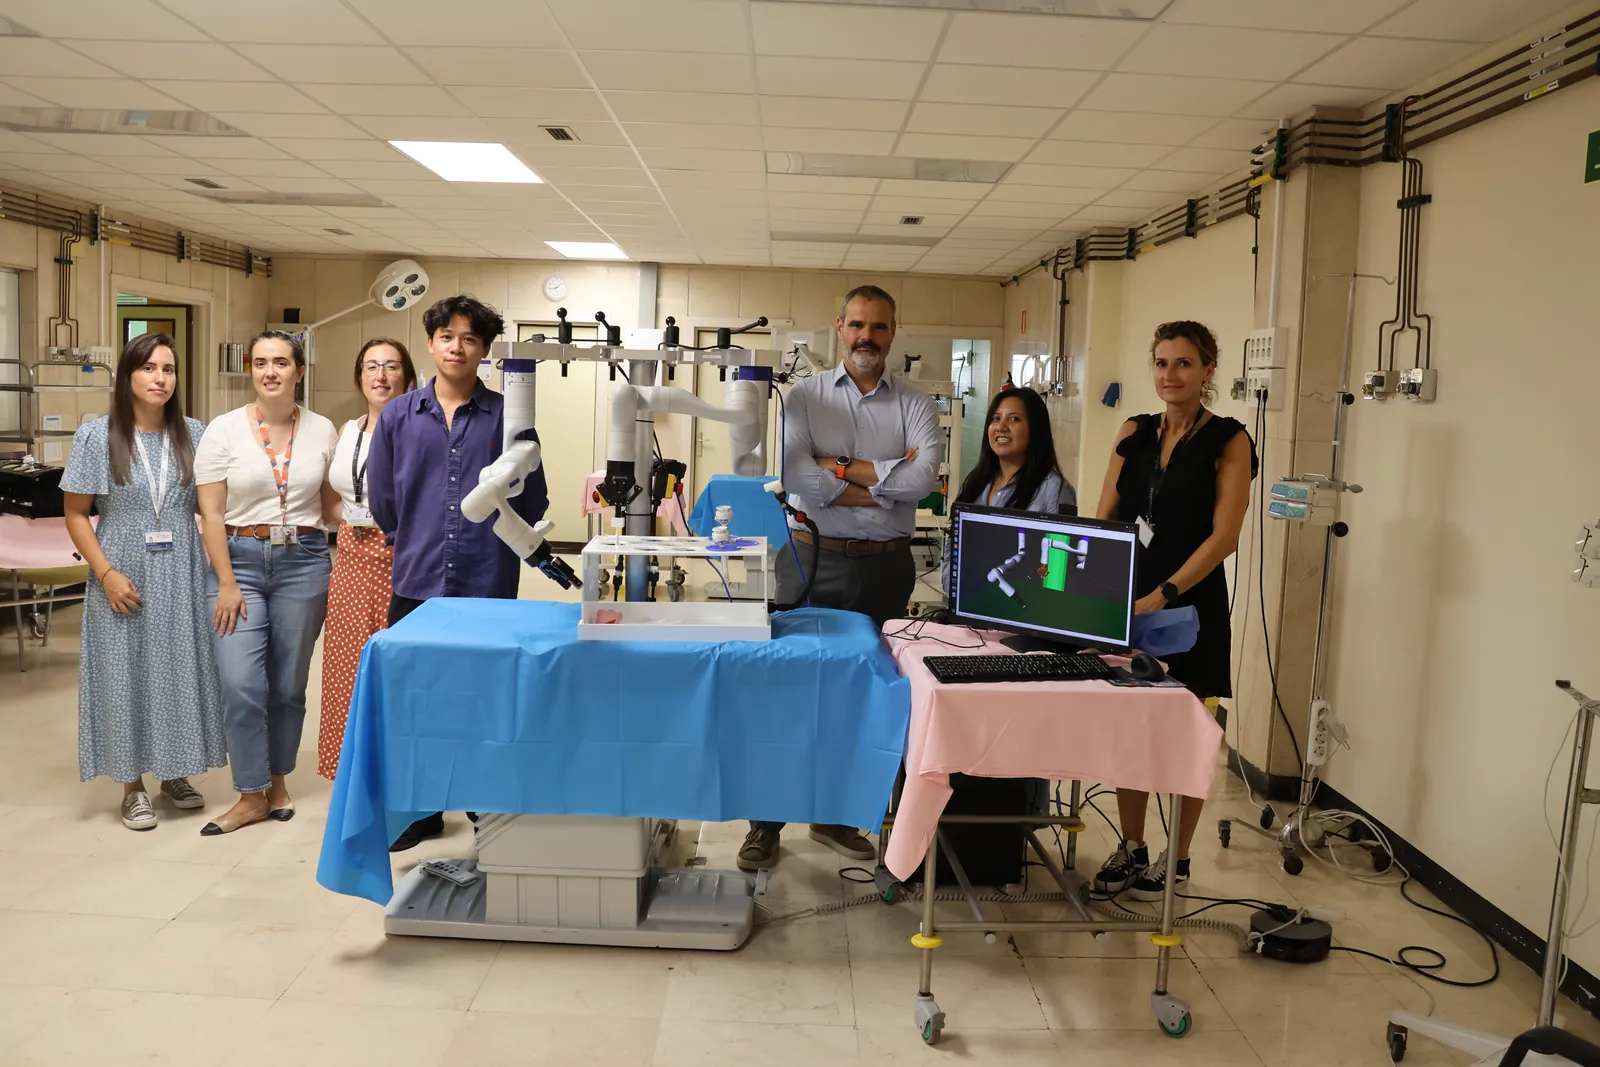
The Autonomous Laparoscopic Surgical Robot is a dual-arm robotic platform built on two Kinova Gen2 arms with a support structure of our own design. We developed it to bring intelligent autonomy to minimally invasive surgery. The whole system is engineered in-house and its core strength is the software: autonomous suturing and precision cutting, real-time obstacle avoidance and measurement inside the surgical field, always under the surgeon’s supervision.
Results
- 98% collision-free operation. The real-time obstacle avoidance system recognises and avoids the robot’s own arms, the organs and restricted anatomical zones, preventing surgical errors before they happen.
- Up to 75% less fatigue-related risk. By handing repetitive, high-precision movements to the autonomous system, surgeon fatigue drops significantly in long procedures, which directly improves patient safety.
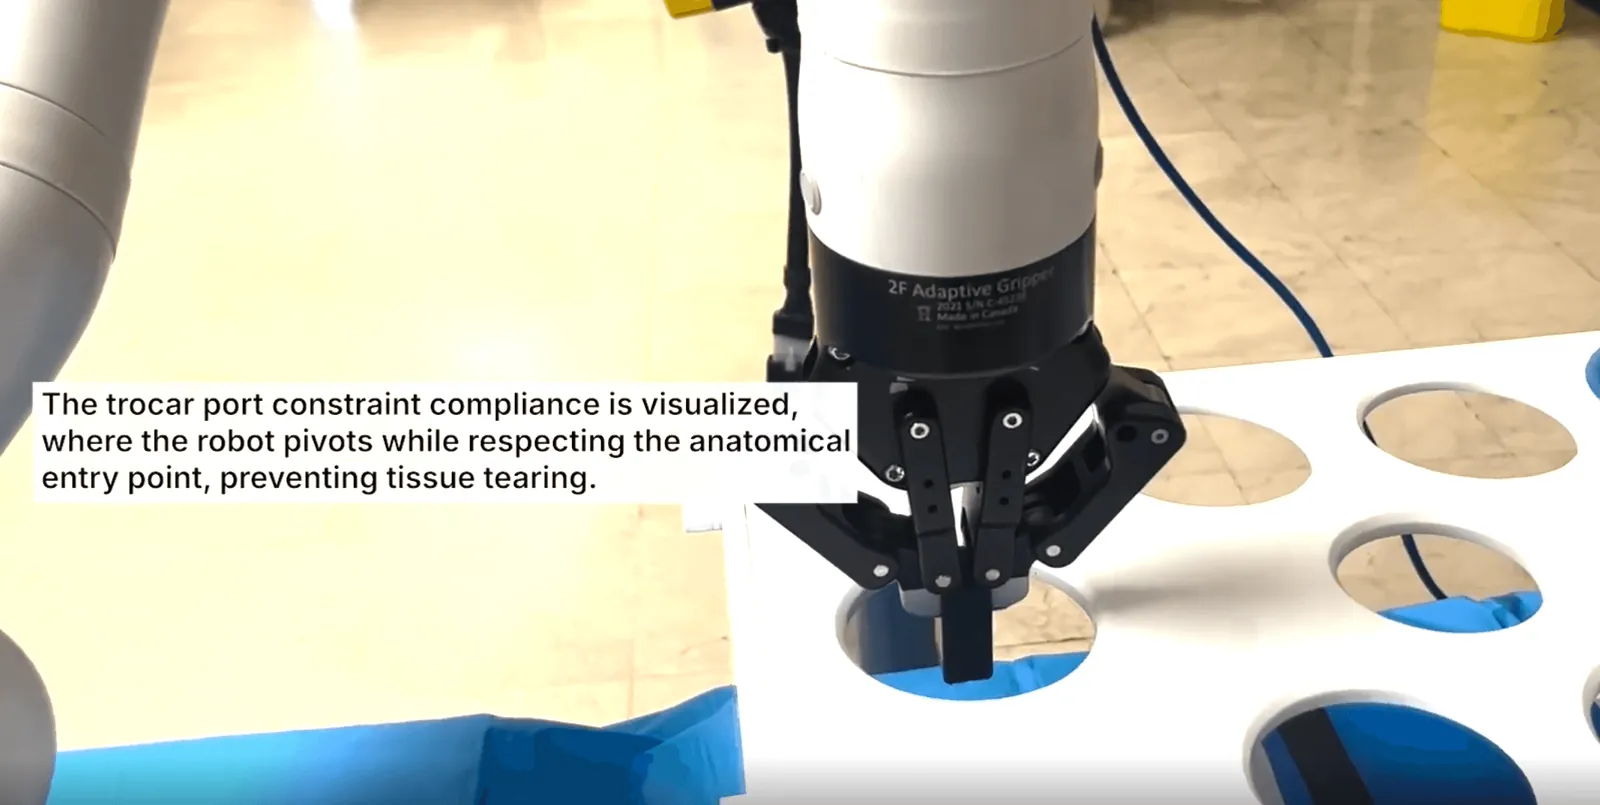
- Under 0.5 mm displacement at the trocar port. The constraint compliance layer keeps unintended lateral forces at the trocar entry point below 0.5 mm, protecting the patient from tissue tearing during both manual and autonomous movements.
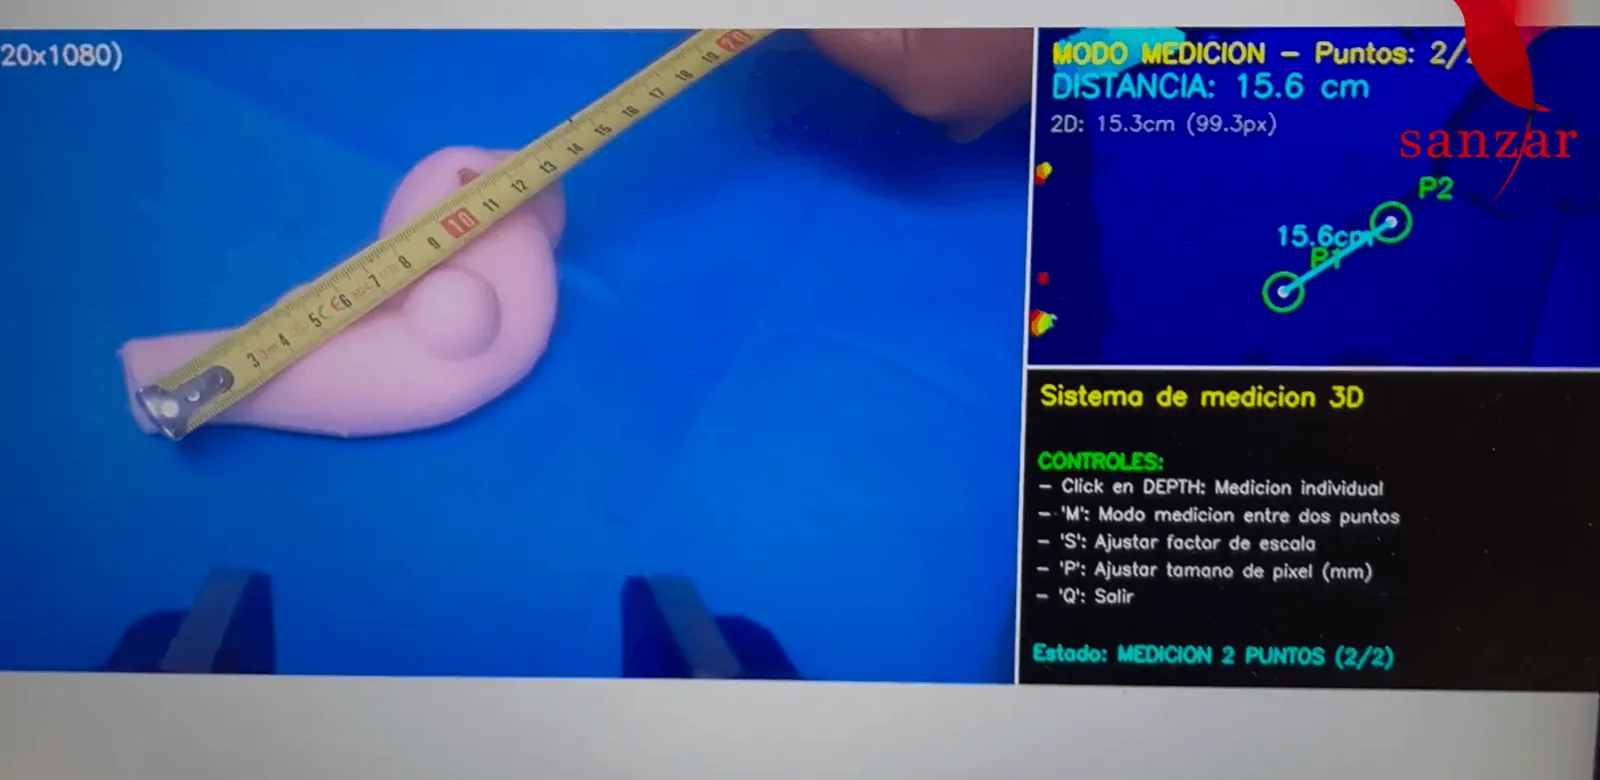
- ±2 mm measurement accuracy. The multimodal measurement system gives real-time distances and dimensions straight from the laparoscopic camera feed, with no extra tools.
Why it matters
Surgical errors and long procedure times are two of the biggest challenges in minimally invasive surgery. This system tackles both: it brings intelligent autonomy into the operating room while keeping the surgeon firmly in control.
The project has been tested at Hospital Virtual Valdecilla in Santander, and you can read more about it in Medicina Cantabria (in Spanish): IDIVAL and Hospital Virtual Valdecilla drive a prototype for autonomous robotic surgery.
If you would like to know more or are interested in working with us on the project, get in touch.